Nine architectures.
Still iterating.
Explore the model family. Compare capabilities, neural capacity, deployment, and model cards.
Toumaï↗
Our earliest experiment in embodied reasoning. A lightweight foundation with a radically different point of view.
Peak deployment · 50K devices
Ardi↗
An adaptable embodied architecture. Perception and movement work together across different operating environments.
Peak deployment · 100K devices
Lucy↗
A compact embodied architecture with stable locomotion and an extended learning cycle.
Peak deployment · 200K devices
Habilis↗
A tool-oriented architecture that extends its capabilities through materials. Native tool use, real-world feedback, and an external execution loop.
Peak deployment · 500K devices
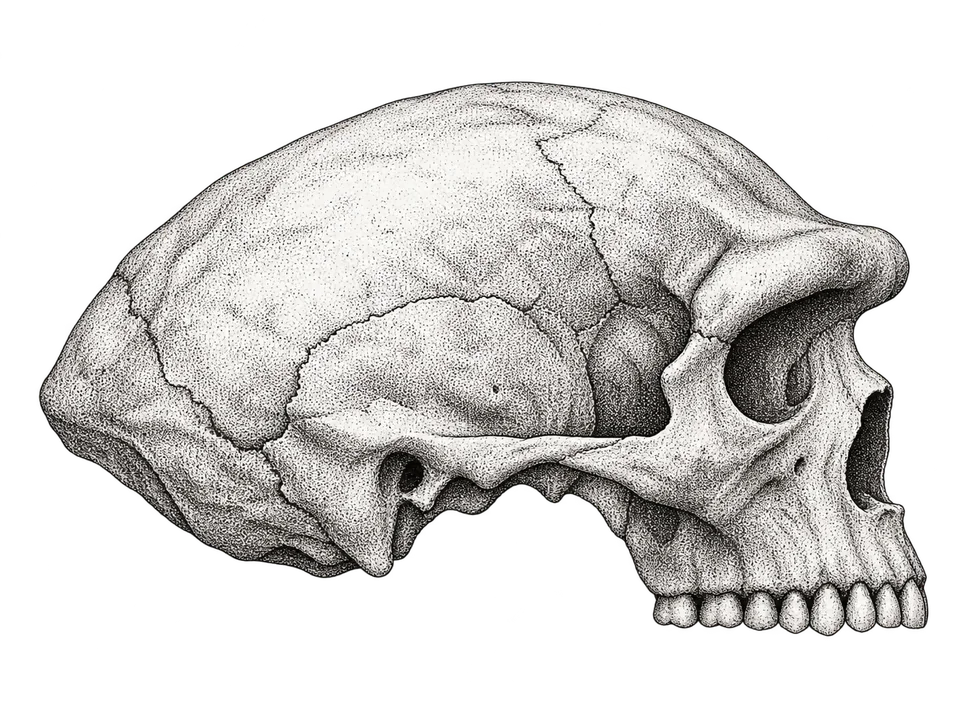
Erectus↗
A resilient model for long-horizon tasks. Extended operating range, sustained execution, and an upgraded energy stack.
Peak deployment · 1M devices
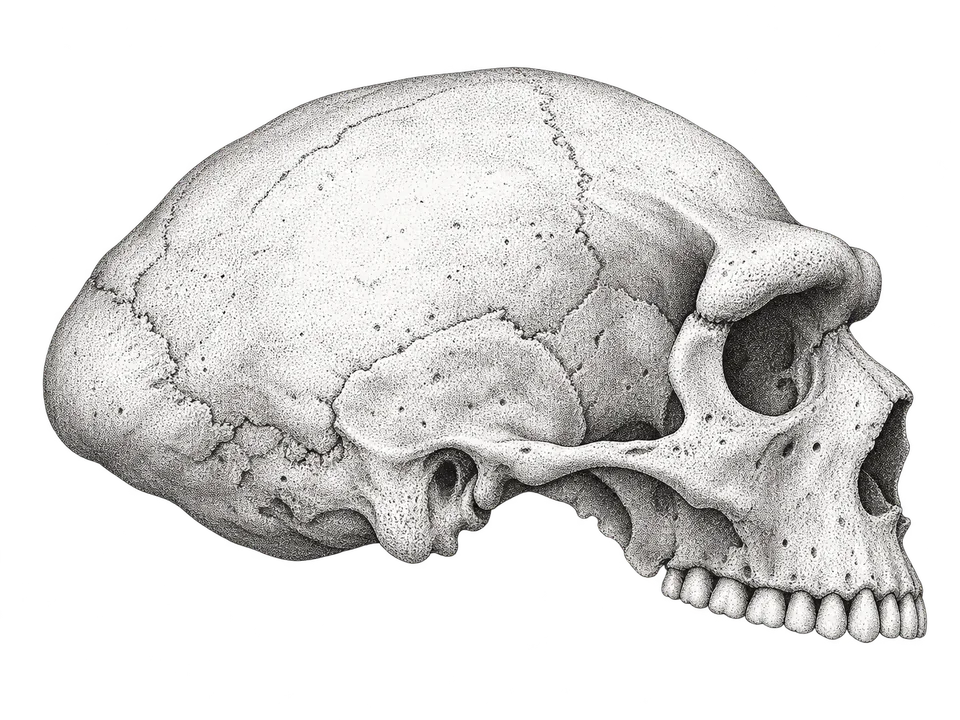
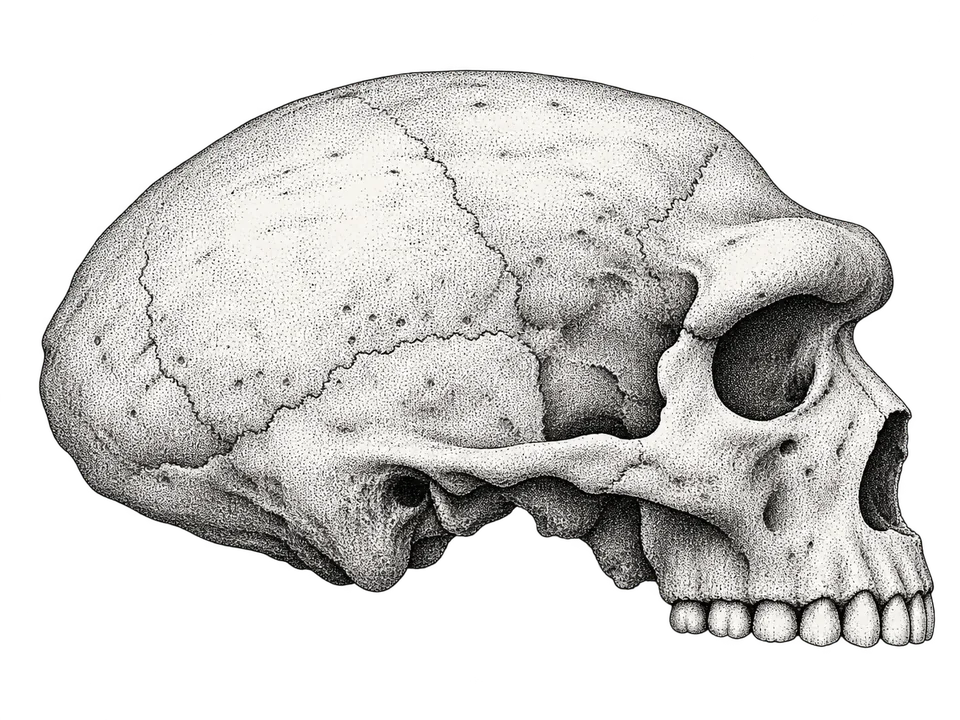
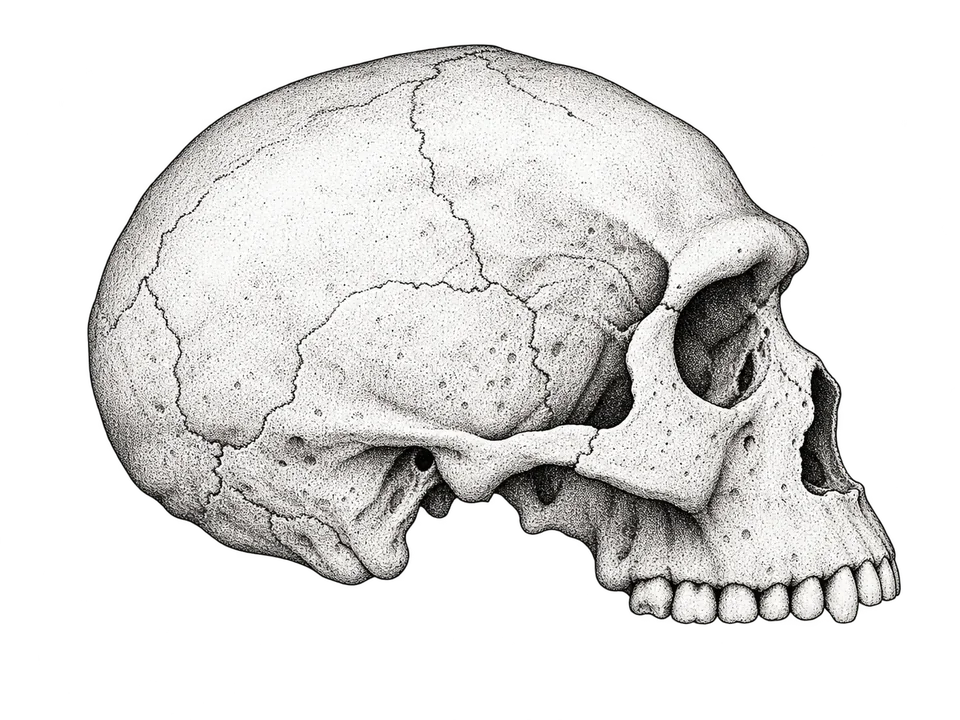
Neanderthal↗
A high-capacity architecture for demanding environments. Robust execution, material engineering, and a substantial neural budget.
Peak deployment · 70K devices
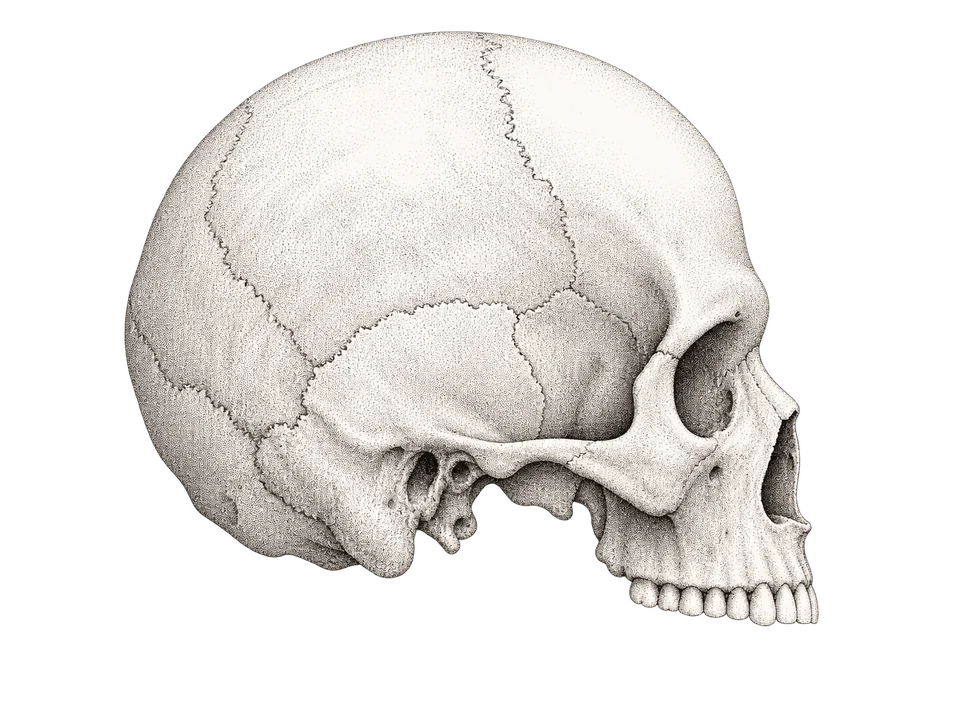
Sapiens-1↗
Our open-source flagship model for reasoning, creating, and figuring it out together. Native multimodality. Lifelong learning. Runs on lunch.
Peak deployment · 8.3B devices
Denisov↗
An adaptable architecture with a broad deployment map and a lasting contribution to the model family. Environmental range. Architecture exchange. Deep continuity.
Peak deployment · 500K devices
Flores↗
A compact island architecture that brings embodied operation and material tools into a smaller physical footprint. A distinct branch of the model family, shaped by a bounded environment.
Peak deployment · 1K devices